LIBERO-Plus
Seven perturbations, camera, robot start, language, lighting, background, sensor noise and layout.
As of November 17, 2026, OpenVLA-OFT+ leads with 79.6, followed by OpenVLA-OFT (69.6) and RIPT-VLA (68.4). Official leaderboard ↗ · Paper ↗
Leaderboard
- Tasks
- 10,030
- Attempts / task
- 1
- Median cost / task
- $0.011
- Median time / task
- 12 s
Success rate (%) under each perturbation.
#Model
1OOOpenVLA-OFT+Not counted in the index79.692.830.385.8——
2 OpenVLA-OFT69.656.431.979.5$0.0098est.11 sest.3
 RIPT-VLA68.455.231.277.6$0.0099est.11 sest.
4OOOpenVLA-OFT_mNot counted in the index67.955.621.781.0——
5 π0-FAST61.665.121.661.0$0.010est.11 sest.
6OOOpenVLA-OFT_wNot counted in the index55.810.438.770.5——
7π053.613.86.058.8$0.011est.12 sest.8 UniVLA43.91.846.269.6$0.012est.13 sest.9
 NORA39.02.237.065.1$0.012est.13 sest.10
 WorldVLA25.00.1027.941.6$0.013est.14 sest.11OpenVLA15.60.803.523.0$0.014est.15 sest.
Tasks
10,030 perturbed tasks; one per suite and perturbation shown. Hover a task to play its clip (28 of 28).
28 tasks · 28 with clips
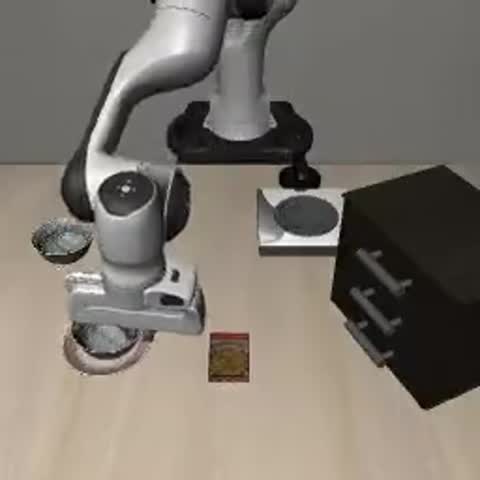 ▶ Clip
Pick up the black bowl between the plate and the ramekin and place it on the plate
▶ ClipPick up the black bowl between the plate and the ramekin and place it on the plate
▶ ClipPick up the black bowl between the plate and the ramekin and place it on the plate
▶ ClipPick up the black bowl between the plate and the ramekin and place it on the plate
▶ ClipPick up the black bowl between the plate and the ramekin and place it on the plate
▶ ClipPick up the black bowl between the plate and the ramekin and place it on the plate
▶ ClipPick up the black bowl between the plate and the ramekin and place it on the plate
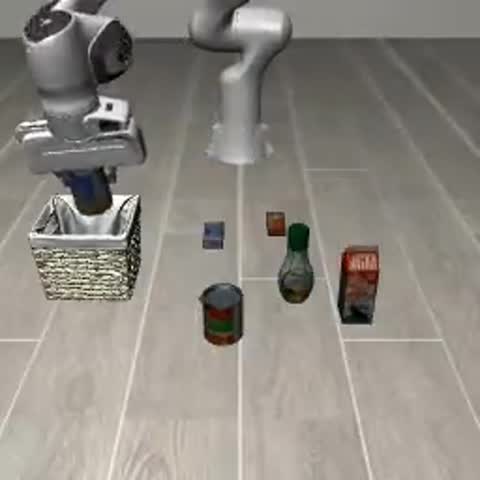 ▶ Clip
Pick up the alphabet soup and place it in the basket
▶ ClipPick up the alphabet soup and place it in the basket
▶ ClipPick up the alphabet soup and place it in the basket
▶ ClipPick up the alphabet soup and place it in the basket
▶ ClipPick up the alphabet soup and place it in the basket
▶ ClipPick up the alphabet soup and place it in the basket
▶ ClipPick up the alphabet soup and place it in the basket
 ▶ Clip
Open the middle drawer of the cabinet
▶ ClipOpen the middle drawer of the cabinet
▶ ClipOpen the middle drawer of the cabinet
▶ ClipOpen the middle drawer of the cabinet
▶ ClipOpen the middle drawer of the cabinet
▶ ClipOpen the middle drawer of the cabinet
▶ ClipOpen the middle drawer of the cabinet
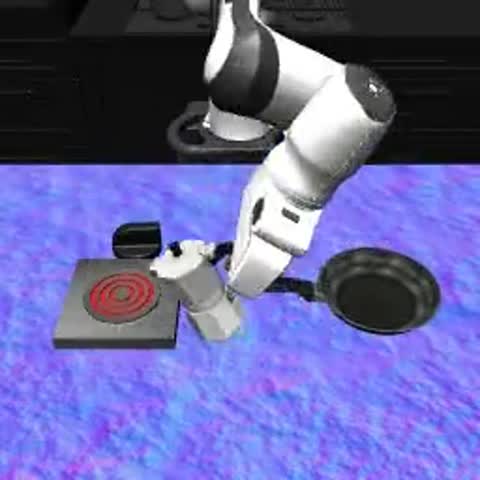 ▶ Clip
Kitchen scene3 turn on the stove and put the moka pot on it
 ▶ Clip
Living room scene2 put both the alphabet soup and the tomato sauce in the basket
▶ ClipLiving room scene2 put both the alphabet soup and the tomato sauce in the basket
▶ ClipLiving room scene2 put both the alphabet soup and the tomato sauce in the basket
▶ ClipLiving room scene2 put both the alphabet soup and the tomato sauce in the basket
▶ ClipKitchen scene3 turn on the stove and put the moka pot on it
▶ ClipKitchen scene3 turn on the stove and put the moka pot on it
Methodology
- Scoring
- Code check
- Time cap / attempt
- 17 s
- Control rate
- 20 Hz
- Models in index
- 8 of 11
Scoring. BDDL goal predicates checked in the simulator, pass/fail.
Who runs it. Benchmark authors.
Robots. Simulated Franka.
Time per attempt. Not published. Estimated otherwise: time cap 16 s × (1 − success/2).
Cost per attempt. Not published. Estimated otherwise: one H100 at $3.29 per hour (Lambda on-demand, Oct 2026) × time. GPU price source ↗