Pick & Place-NextTo
 MolmoSpacesMolmoBot v1.5/v2
- Robot
- Franka FR3
- Trials
- 1,000
- Time limit
- 30 s
Pick up the object and place it next to the reference object.
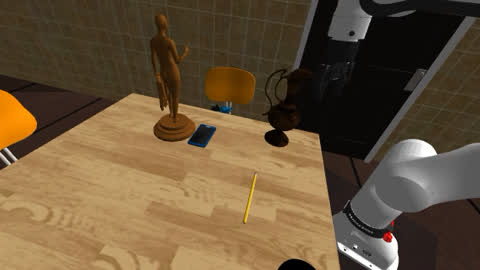
Official MolmoSpaces clipSource ↗
SuccessPass/fail
Object's xy bounding box surface-to-surface gap to the receptacle within, object supported by the same surface as the receptacle, receptacle moved at most 0.05 m and tilted at most 45 deg.
Full criteria and notes
- Full success check
- Object's xy bounding box surface-to-surface gap to the receptacle within [0, 0.05 m (+0.01 slack)], object supported by the same surface as the receptacle, receptacle moved at most 0.05 m and tilted at most 45 deg (PickAndPlaceNextToTask.get info). Episode counts as success if this holds at any step (oracle success, the ranking metric); at-end success is also reported for some tasks. Benchmark: molmospaces-bench-v2/procthor-objaverse/FrankaPickandPlaceNextToHardBench (20260305), filament.
- Scoring
- 1 per episode; task score = oracle successes / episodes x100.
- Trials
- ~1,000 distinct episodes, each run once (median n=1000; varies by entry).
Results on this task
ModelPick and place
MagicBrain + Qwen3.7-Plus84.7
 Awomo-0.5I71.0Awomo-0.5V58.9
EchoPolicy-0 + Gemini-3.8-Flash55.6
PrimeR054.6
WALL-OSS-0.546.0
Cosmic + Gemini-ER44.7
Phoenix + Gemini-ER43.8
Psi-R241.5
Vana-Policy36.1
 Cosmos3-Nano-Policy35.2
TiPToP + Gemini-ER33.2
PAT + Qwen3.8-27B31.3
PRTS-Droid27.7
PAT-RoboLab + Qwen3.8-27B24.7
 MolmoAct223.3
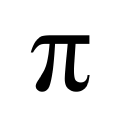 π0.513.6π012.5π0-FAST10.9
LAP-VLA6.6