Open
 MolmoSpacesMolmoSpaces v1
- Robot
- Franka FR3
- Trials
- 1,000
- Time limit
- 30 s
- Step limit
- 450
Open the articulated object (cabinet, drawer, door, ...).
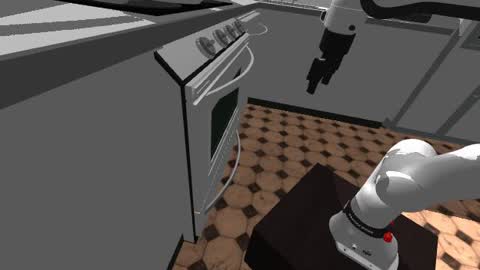
Official MolmoSpaces clipSource ↗
SuccessPass/fail
The simulator's success check passes at any step of the episode.
Full criteria and notes
- Full success check
- Max normalized joint opening |q|/range over the target articulation's joints >= task success threshold (0.15 in base open task configs; dataclass default 0.20; per-episode JSON governs) (OpeningTask.judge success). Episode counts as success if this holds at any step (oracle success, the ranking metric); at-end success is also reported for some tasks. Benchmark: molmospaces-bench-v1/ithor/FrankaOpenDataGenConfig (20260123); horizon 450.
- Scoring
- 1 per episode; task score = oracle successes / episodes x100.
- Trials
- ~1,000 distinct episodes, each run once (median n=1000; varies by entry).
Results on this task
ModelOpen
EchoPolicy-0 + Gemini-3.8-Flash70.2
 Awomo-0.5V62.4
Cosmic + Gemini-ER58.5
Awomo-0.5I49.3CAPopen + Gemini-ER41.9
Phoenix + Gemini-ER37.3
ZoeInside-VLA36.6
Vana-Policy35.1
 Cosmos3-Nano-Policy32.0
PrimeR027.8
MagicBrain + Qwen3.7-Plus27.7
 π0.522.7
PAT + Qwen3.8-27B22.4
PAT-RoboLab + Qwen3.8-27B17.0
WALL-OSS-0.516.8
PRTS-Droid12.0
 MolmoAct211.7
LAP-VLA11.4
π0-FAST11.1π011.0Psi-R29.0