 RoboLab-120
NVIDIA Seattle Robotics LabMaintainer ↗120 tasks. Difficulty (simple, moderate, complex) and skill (visual, relational, procedural), plus reworded instructions.
As of November 17, 2026, AMP1 leads with 86.0, followed by SenseNova-RoboRSI (57.1) and Lakeside (51.0). Official leaderboard ↗ · Paper ↗
Leaderboard
- Tasks
- 120
- Attempts / task
- 10
- Median cost / task
- $0.068
- Median time / task
- 72 s
Overall vs speed
Published time per task attempt
Cost isn’t published
RoboLab-120 doesn’t report cost per attempt for enough models to chart. The table shows Playground’s estimates, marked est.; Methodology explains how they’re made.
Success rate (%), 10 attempts per task.
 SenseNova-RoboRSI57.159.456.250.6$17.74est.65 sest.
 Praxis-146.246.947.940.0$0.064est.70 sest.6
 FLUX 3 Action42.949.139.228.2$0.065est.72 sest.7
 Cosmic42.346.640.031.8$0.066est.72 sest.
 Cosmos3-Nano-Policy36.840.635.425.3$0.068est.74 sest.12Phoenix34.442.825.622.9$0.069est.76 sest.
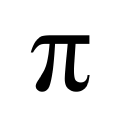 π0.528.029.731.513.5$0.015est.17 s16DreamZero25.726.130.014.1$0.073est.80 sest.17Cosmos3-Edge-Policy22.925.623.311.8$0.074est.81 sest.18π0-FAST15.520.213.32.9$0.018est.19 s19GR00T N1.67.28.87.90.00$0.080est.88 sest.20π05.07.23.60.00$0.029est.32 s21PaliGemma-binning3.43.44.90.00$0.082est.90 sest.
Tasks
120 tasks. Hover a task to play its clip (15 of 120).
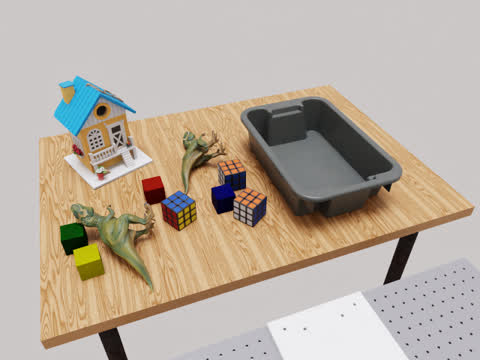
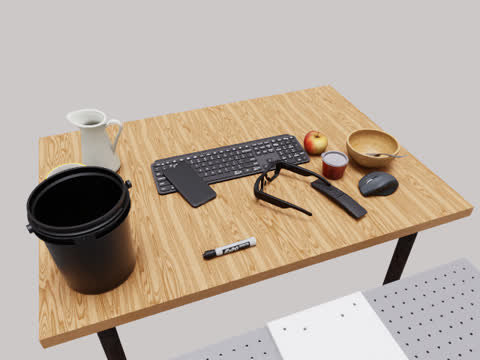
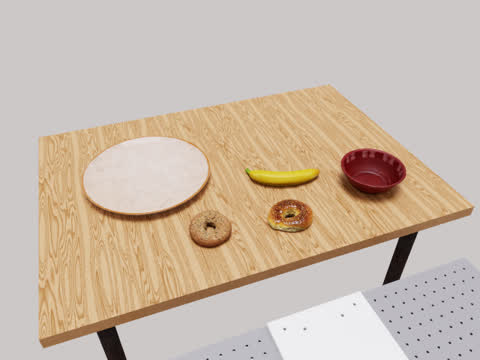
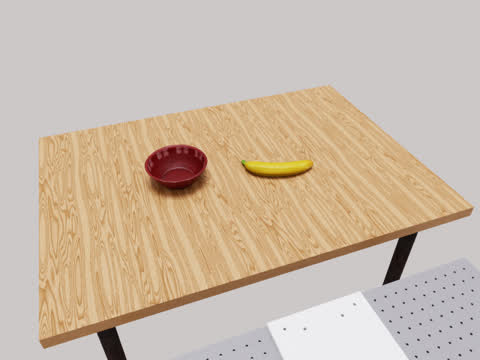
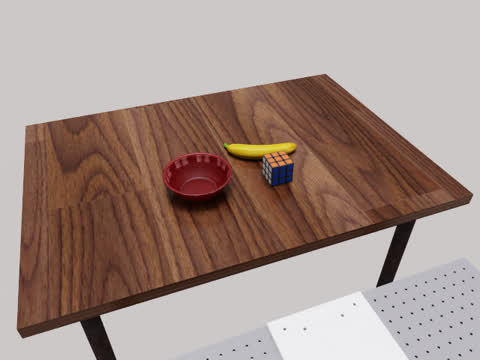
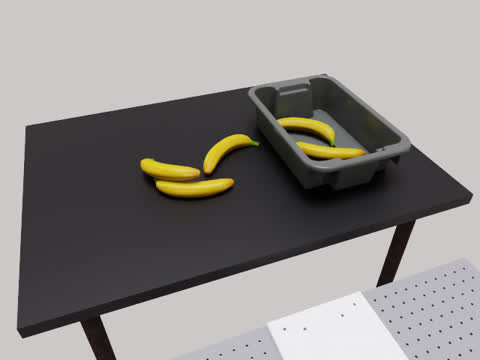
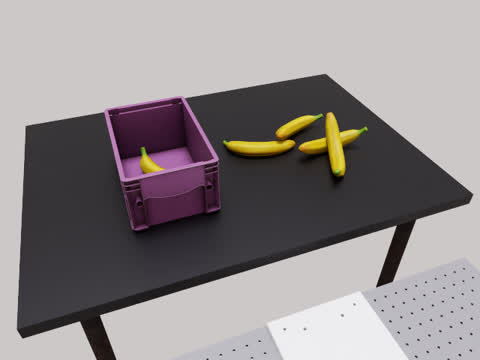
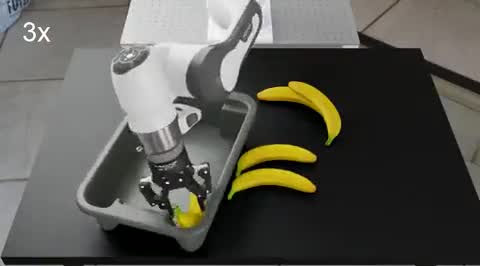 ▶ Clip
 ▶ Clip
 ▶ Clip
 ▶ Clip
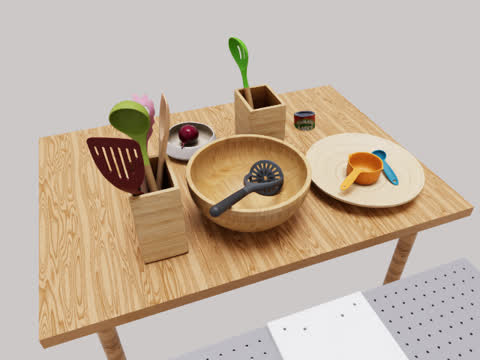
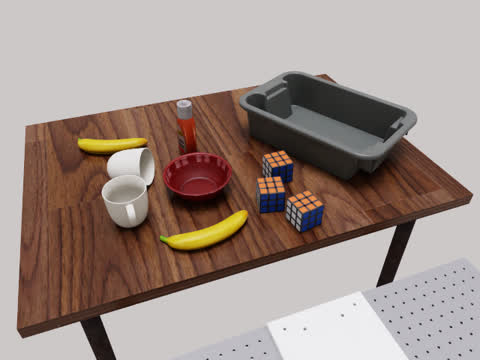
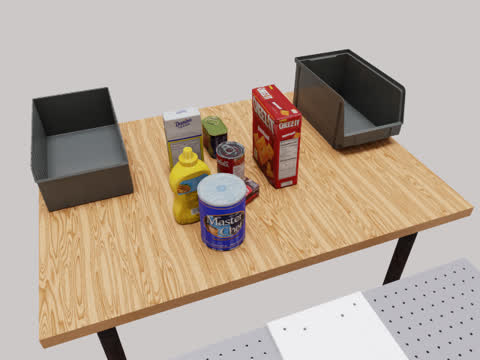
 ▶ Clip
 ▶ Clip
 ▶ Clip
 ▶ Clip
Methodology
- Scoring
- Code check
- Time cap / attempt
- 1 min 31 s
- Control rate
- 15 Hz
- Models in index
- 13 of 21
Scoring. Simulator end-state check per task, plus a subtask progress score.
Who runs it. NVIDIA runs or cross-checks entries.
Robots. Simulated Franka (DROID setup).
Time per attempt. Published or measured for 3 of 13 models. Estimated otherwise: time cap 91 s × (1 − success/2).
Cost per attempt. Not published. Estimated otherwise: one H100 at $3.29 per hour (Lambda on-demand, Oct 2026) × time; GPT-6 Astra's median published cost per attempt on other boards. GPU price source ↗