Cooking pick pasta tool
 RoboLab-120Simple · Relational and visual
- Robot
- Franka (DROID)
- Trials
- 10
- Time limit
- 60 s
- Step limit
- 900
Move the pink tool from this utensil container to the other utensil holder.
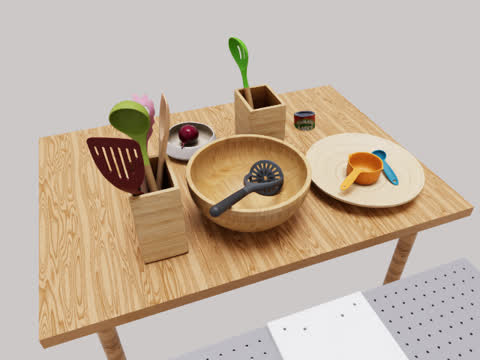
Official scene renderSource ↗
SuccessPass/fail
The simulator's end-state check passes; see the full check below.
Full criteria and notes
- Full success check
- Success when pink spaghetti spoon inside storage_box_01 (centroid inside the container's local bounding box with open-top slack) and the gripper has released them, in contact with the container. Checked every step (episode ends at first success; 60 s horizon).
- Instruction variants
- Vague: Move the pink tool over to the other container. · Specific: Remove the pink pasta tool from its current utensil container and place it in the other utensil holder.
- Scoring
- Pass/fail, plus a subtask progress score from 0 to 1.
- Trials
- 10 episodes per task.